What does this application do?
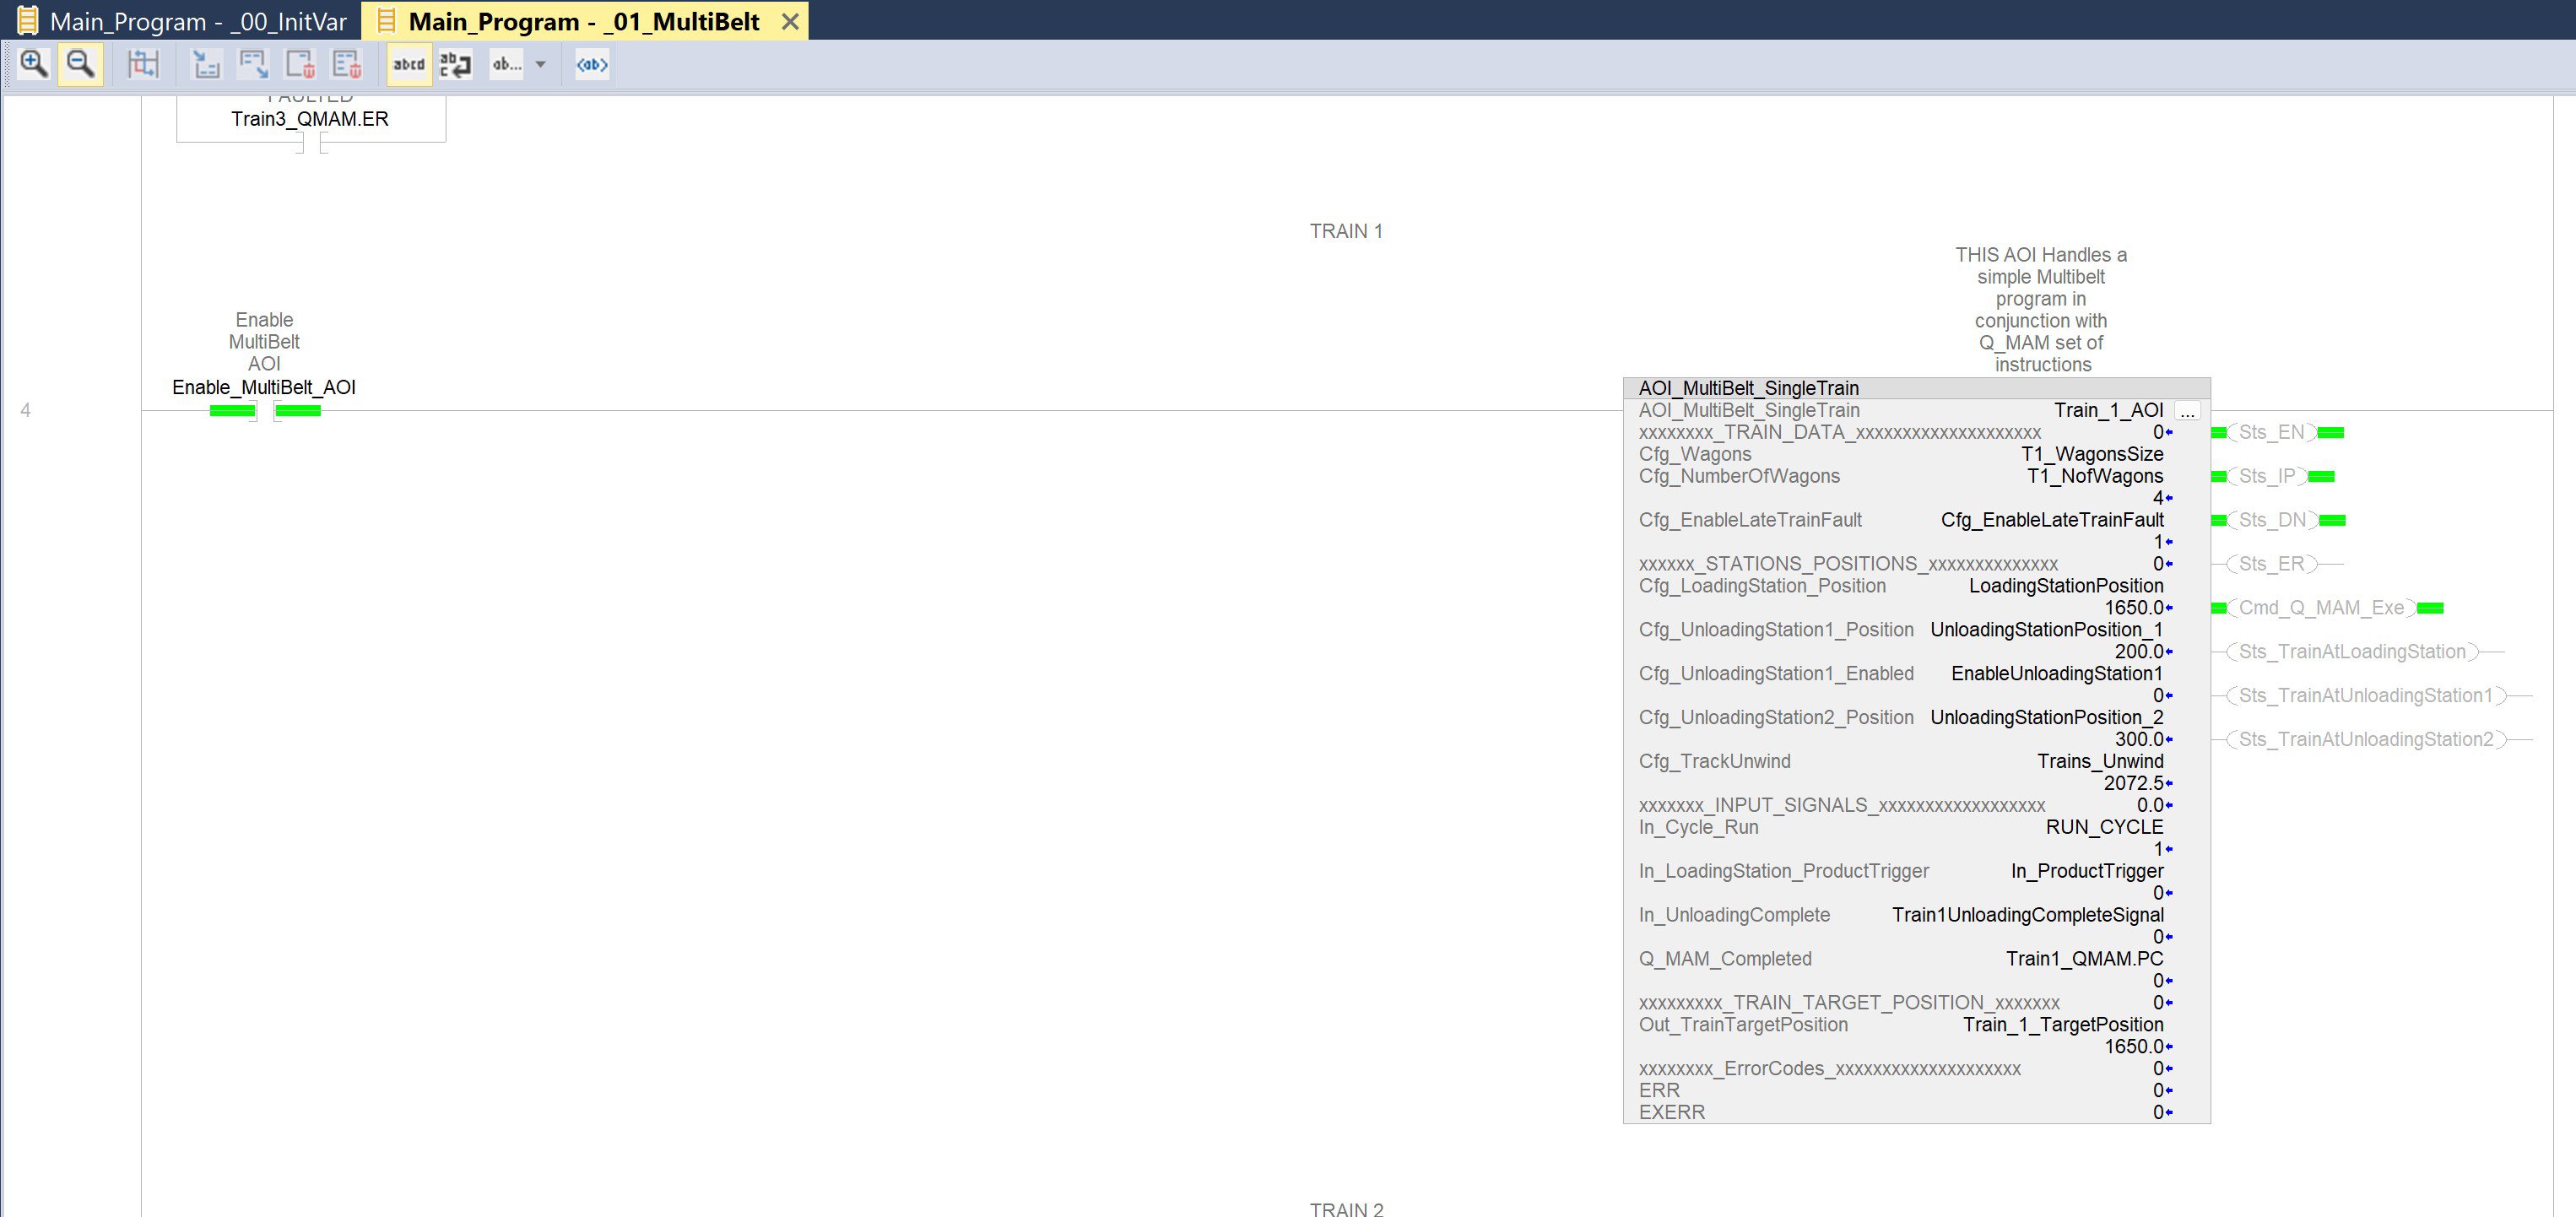
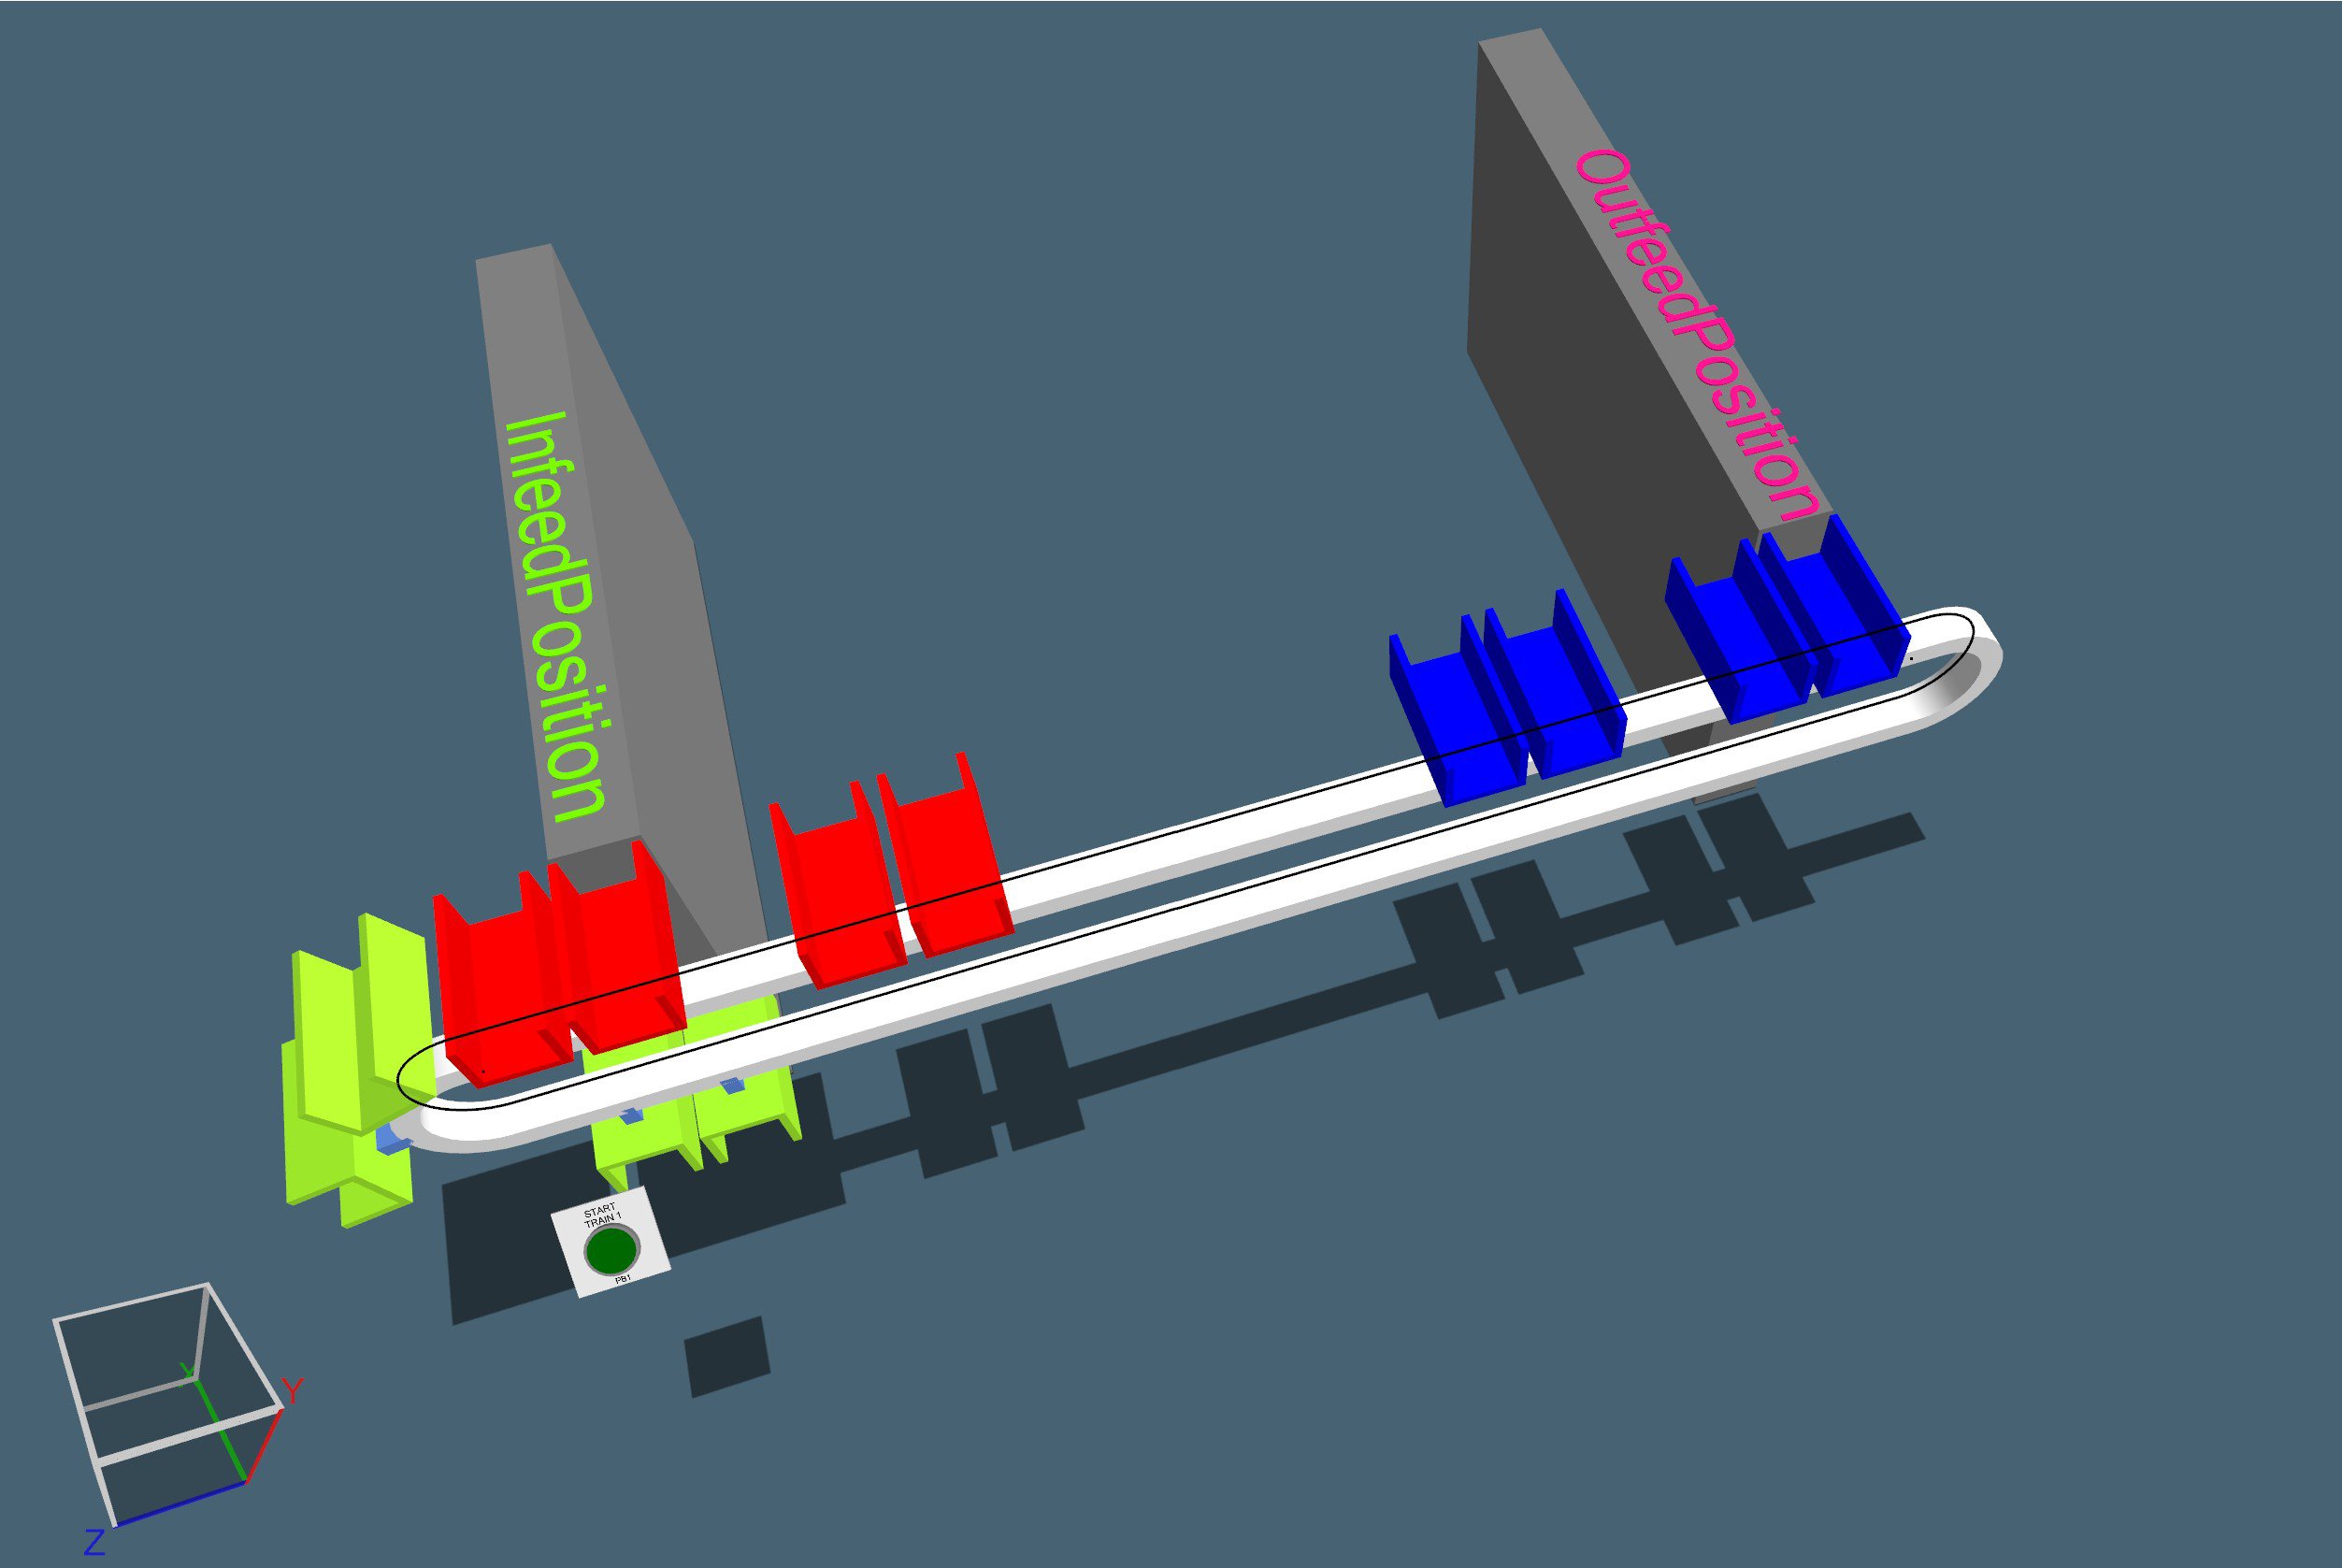
The project implements a motion control application for a MultiBelt system made up of three synchronized trains or carts on a circular path. Each train travels between a loading station and one or two unloading stations, keeping its distance from the preceding train to prevent collisions or approaches below a configured minimum distance.
The application runs on a GuardLogix/ControlLogix/CompactLogix controller and uses two main motion devices: Drive_1 and Drive_2. The train axes are named Ax_Train1, Ax_Train2 and Ax_Train3, and there is also an infeed belt axis called In_Belt along with the Ax_Converter axis, all grouped in the Axes motion group.
The logic is organized into three blocks. Main_Program governs the overall sequence: it initializes parameters and handles start-up, stop, fault reset, product simulation, MultiBelt coordination and axis management. Main_Motion_Prg executes the Q_MAM motion commands and publishes command positions for visualization or external integration. SafetyProgram manages the Safe Torque Off function of the trains through encoded safety AOIs.
The objective of this document is to commission the three-train MultiBelt application (or a configuration adapted to the need), run the cycle, observe the motion and stop it in a controlled way. The intended use mode is an environment that supports motion control, with a synchronized axis group, configured drives and a validated Safe Torque Off chain.
The problem it solves is the coordination of several independent movers on the same closed track. The logic prevents a train from catching up with the one ahead by calculating the circular distance between axes, applying a minimum distance, switching to queued mode when the gap shrinks, and propagating position feedforward from the preceding axis to the following train.