
Motion Error Codes .ERR
This table lists the error codes for motion instructions.
IMPORTANT:
This table provides a list of Motion error codes. Some error codes may be
associated with Motion features that are not available in the current release
of
FactoryTalk Design Studio
. For information about Motion feature
availability, see the FactoryTalk Design Studio
Release Notes.Motion Instruction Error Codes Descriptions
Error | Corrective Action or Cause | Notes |
|---|---|---|
1 | Reserved Error Code 1 | Reserved for future use. |
2 | Reserved Error Code 2 | Reserved for future use. |
3 | Look for another instance of this type of instruction. See if its
EN bit is on but its DN and ER bits are off (enabled but not
done or erred). Wait until its DN or ER bit turns on. | Execution Collision You cannot execute an instruction by using the same control word
as another instruction if the other instruction is not done or
has an error. Regardless, it is recommended that each
instruction has a unique control word. |
4 | Open the servo loop before you execute this instruction. | Servo On State Error |
5 | Close the servo loop before you execute this instruction. | Servo Off State Error For a motion coordinated instruction, refer to the online help
for the instruction for extended error code definitions. They
identify which axis caused the error. Example: If the extended error code is zero, check the axis for
index zero of the coordinate system. |
6 | Disable the axis drive. | Drive On State Error |
7 | Execute a Motion Axis Shutdown Reset (MASR) instruction or direct
command to reset the axis. | Shutdown State Error For a motion coordinated instruction, refer to the online help
for the instruction for extended error code definitions. They
identify which axis caused the error. Example: If the extended error code is zero, check the axis for
index zero of the coordinate system. |
8 | The configured axis type is not correct. | Wrong Axis Type For a motion coordinated instruction, refer to the online help
for the instruction for extended error code definitions. They
identify which axis caused the error. Example: If the extended error code is zero, check the axis for
index zero of the coordinate system. |
9 | The instruction tried to execute in a direction that aggravates
the current overtravel condition. | Overtravel Condition |
10 | The leader axis reference is the same as the follower axis reference
or the Leader Axis is also an axis in the Save Coordinate
System. | Leader Axis Conflict |
11 | At least one axis is not configured to a physical motion module
or has not been assigned to a Motion Group. | Axis Not Configured For single axis instructions: the Extended Error code for MAG, MDAC, MAPC, MAM, MAJ, MATC, and
MCD is defined as: 1 = Follower axis 2 = Leader Axis For the MAM, MCD, and MAJ instructions in time driven mode, the
axis being moved is a follower axis. For multi-axes instructions: the Extended Error code for MDCC, MCLM, MCCM, MCCD, and MCPM is
defined as: The axis number in the coordinate system where 0 = 1st axis 2 = Leader Axis or 3rd Follower Axis |
12 | Messaging to the servo module failed. | Servo Message Failure |
13 | Refer to the online help for the instruction for extended error
code definitions. Example: An MAJ instruction has an ERR = 13 and an EXERR = 3. In
this case, change the speed so that it’s in range. 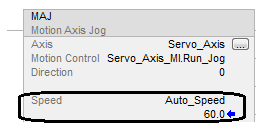 | Parameter Out Of Range An EXERR = 0 means the first operand of the instruction is
outside its range. |
14 | The instruction cannot apply the tuning parameters because of an
error in the run tuning instruction. | Tune Process Error |
15 | The instruction cannot apply the diagnostic parameters because of
an error in the run diagnostic test instruction. | Test Process Error |
16 | Wait until the homing process is done. For coordinated move instructions, it identifies which axis
caused the error. | Home In Process Error |
17 | The instruction tried to execute a rotary move on an axis that is
not configured for rotary operation. | Axis Mode Not Rotary |
18 | The axis type is configured as unused. | Axis Type Unused |
19 | The motion group is not in the synchronized state. This could be
caused by a missing or misconfigured servo module. | Group Not Synchronized Group sync status is only cleared on a group overlap or CST loss
fault. |
20 | The axis is in the faulted state. | Axis In Faulted State |
21 | The group is in the faulted state. | Group In Faulted State |
22 | Stop the axis before you execute this instruction. | Axis In Motion |
23 | An instruction attempted an illegal change of dynamics. | Illegal Dynamic Change |
24 | Take the controller out of test mode. | Illegal Controller Mode |
25 | Either one of these could be the reason for the error:
| Illegal Instruction |
26 | The cam array is of an illegal length. | Illegal Cam Length |
27 | The cam profile array is of an illegal length. | Illegal Cam Profile Length |
28 | You have an illegal segment type in the cam element. | Illegal Cam Type The .SEGMENT field of Motion Instruction identifies which cam
profile element contains the invalid segment type. A .SEGMENT = 3 means the 4th element (or [3]) of the cam profile
array contains the invalid segment type. |
29 | You have an illegal order of cam elements. | Illegal Cam Order The .SEGMENT field of Motion Instruction identifies which cam
profile element contains the invalid (non-ascending) leader
value. A .SEGMENT = 3 means the 4th element (or [3]) of the cam profile
array contains the invalid (non-ascending) leader value. |
30 | You tried to execute a cam profile while it is being
calculated. | Cam Profile Being Calculated |
31 | The cam profile array you tried to execute is in use. | Cam Profile Being Used |
32 | The cam profile array you tried to execute has not been
calculated. | Cam Profile Not Calculated |
33 | A MAM - Leader Offset move was attempted without a Position CAM
in process. | Position Cam Not Enabled |
34 | A MAH instruction is trying to start while a registration is
already running. | Registration in Progress |
35 | The specified execution target exceeds the number of Output Cam
targets configured for the axis. | Illegal Execution Target |
36 | Either the size of the Output Cam array is not supported or the
value of one of its members is out of range. | Illegal Output Cam ExErr#1: Output bit less than 0 or greater than 31. ExErr#2: Latch type less than 0 or greater than 3. ExErr#3: Unlatch type less than 0 or greater than 5. ExErr#4: Left or right position is out of cam range and the latch
or unlatch type is set to `Position’ or `Position and
Enable’. ExErr#5: Duration less than or equal to 0 and the unlatch type is
set to `Duration’ or `Duration and Enable’. ExErr#6: Enable type less than 0 or greater than 3 and the latch
or unlatch type is set to `Enable’, `Position and Enable’, or
`Duration and Enable’. ExErr#7: Enable bit less than 0 or greater than 31 and the latch
or unlatch type is set to `Enable’, `Position and Enable’, or
`Duration and Enable’. ExErr#8: Latch type is set to `Inactive’ and unlatch type is set
to either `Duration’ or `Duration and Enable’. |
37 | Either the size of the Output Compensation array is not supported
or the value of one of its members is out of range. The array index associated with errors 36 and 37 are stored in
.SEGMENT of the Motion Instruction data type. Only the first of
multiple errors are stored. The specific error detected is
stored in Extended Error Code. With the ability to dynamically modify the Output Cam table, the
Illegal Output Cam error 36 can occur while the MAOC is
in-process. In general, the cam elements where an error was
detected will be skipped. The following are exceptions and will
continue to be processed. Error 2, Latch Type Invalid. Latch Type defaults to Inactive. Error 3, Unlatch Type Invalid. Unlatch Type defaults to
Inactive. Error 8, with Unlatch Type of Duration and Enable. Will behave as
an Enable Unlatch type. | Illegal Output Compensation ExErr#1: Mode less than 0 or greater than 3. ExErr#2: Cycle time less than or equal to 0 and the mode is set
to `Pulsed’ or `Inverted and Pulsed’. ExErr#3: Duty cycle less than 0 or greater than 100 and the mode
is set to `Pulsed’ or `Inverted and Pulsed’. |
38 | The axis data type is illegal. It is incorrect for the
operation. | Illegal Axis Data Type |
39 | You have a conflict in your process. Test and Tune cannot be run
at the same time. | Process Conflict |
40 | You are trying to run a MSO or MAH instruction when the drive is
locally disabled. | Drive Locally Disabled |
41 | The Homing configuration is illegal. You have an absolute homing
instruction when the Homing sequence is not immediate. | Illegal Homing Configuration |
42 | The MASD or MGSD instruction has timed out because it did not
receive the shutdown status bit. Usually a programmatic problem
caused when either MASD or MGSD is followed by a reset
instruction that is initiated before the shutdown bit has been
received by the shutdown instruction. | Shutdown Status Timeout |
43 | You have tried to activate more motion instructions than the
instruction queue can hold. | Coordinate System Queue Full |
44 | You have drawn a line with three 3 points and no centerpoint
viapoint or plane centerpoint can be determined. | Circular Collinearity Error |
45 | You have specified one 1 point radius or "drawn a line"
centerpoint, viapoint and no centerpoint radius or plane
centerpoint, viapoint can be determined. | Circular Start End Error |
46 | The programmed centerpoint is not equidistant from start and end
point. | Circular R1 R2 Mismatch Error |
47 | Contact Rockwell Automation Support. | Circular Infinite Solution Error |
48 | Contact Rockwell Automation Support. | Circular No Solutions Error |
49 | |R| < 0.01. R is basically too small to be used in
computations. | Circular Small R Error |
50 | The coordinate system tag is not associated with a motion
group. | Coordinate System Not in Group |
51 | You have set your Termination Type to Actual Position with a
value of 0. This value is not supported. | Invalid Actual Tolerance |
52 | At least one axis is currently undergoing coordinated motion in
another coordinate system. | Coordination Motion In Process Error |
53 | Uninhibit the axis. | Axis Is Inhibited For single axis instructions, the Extended Error code for MAG,
MDAC, MAPC, MAM, MAJ, MATC, and MCD is defined as: 1 = Follower axis 2 = Leader Axis For the MAM, MCD, and MAJ instructions in time driven mode, the
axis being moved is a follower axis. For multi-axes instructions, the Extended Error code for MDCC,
MCLM, MCCM, MCCD, MCTO, and MCPM is defined as: The axis number in the coordinate system where 0 = 1st axis 2 = Leader Axis or 3rd Follower Axis |
54 | You cannot start motion if the maximum deceleration for the axis
is zero. For coordinated move instructions, it identifies which axis
caused the error. | Zero Max Decel |
61 | Refer to the online help for the instruction for extended error
code definitions. | Connection Conflict |
62 | Cancel the transform that controls this axis or don’t use this
instruction while the transform is active. | Transform In Progress You cannot execute this instruction if the axis is part of an
active transform. |
63 | Cancel the transform that controls this axis or wait until the
transform is done moving the axis. | Axis In Transform Motion You cannot execute this instruction if a transform is moving the
axis. |
64 | Use a Cartesian coordinate system. | Ancillary Not Supported You cannot use a non-Cartesian coordinate system with this
instruction. |
65 | Once the error occurs, position the axis (or leader axis) within
bounds to execute instructions generating motion on the
axis. This error occurs with MAM, MAPC, MCLM, MCCM, MCPM instructions
and axes that are part of Kinematics transforms. This error
occurs when instruction executes and the absolute position is
outside the overtravel limits. | Absolute position outside the overtravel limits |
66 | Be sure to keep the robot in the arm solution that you configured
it in. You can configure the robot in either a left arm or right
arm solution. | You are attempting to fold back an articulated independent or
dependent two axis robot on itself at the quadrant
boundaries. |
67 | Either one of these could be the reason for the error: 1. You’re trying to move to a place the robot cannot reach. 2. MCT, MCTO, MCTP or MCTPO attempted while at origin. To avoid having the robot fold back on itself or extend beyond
its reach, joint limits are calculated internally by the
firmware for Delta2D, Delta3D and SCARA Delta robots. If you try
and configure a move that violates these limits, this error
occurs. Refer to the online help for the instruction for extended error
code definitions. It identifies which orientation axis caused
the error. | Invalid Transform Position |
68 | Move the joints so that the end of the robot is not at the origin
of the coordinate system. | Transform At Origin You cannot start the transform if the joint angles result in X1 =
0 and X2 = 0. |
69 | Check the maximum speed configuration of the joints. Use target positions that keep the robot from getting fully
stretched or folding back on itself at the origin of the
coordinate system. Move in a relatively straight line through positions where X1 = 0
and X2 = 0. | Max Joint Velocity Exceeded The calculated speed is very high. This happens when the robot
either: gets fully stretched. folds back on itself. moves away from X1 = 0 and X2 = 0 in a different angle than it
approached that position. is configured with the wrong velocity limit. Example: These moves produce this error. 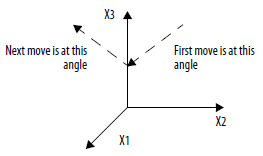 |
70 | Look for source or target axes that are configured as rotary
positioning mode. Change them to linear positioning mode. | Axes In Transform Must Be Linear A transform works only with linear axes. |
71 | Wait until the transform that you are canceling is completely
canceled. | Transform Is Canceling |
72 | Check the target positions. A calculated joint angle is beyond
+/- 360⋅. | Max Joint Angle Exceeded |
73 | Check that each MCT instruction in this chain is producing valid
positions. | Coordinate System Chaining Error This MCT instruction is part of a chain of MCT instructions.
There is a problem with one of the instructions in the
chain. |
74 | Change the orientation to angles that are within +/- 360⋅. | Invalid Orientation Angle |
75 | Use this instruction only with a 1756-L6x controller. | Instruction Not Supported You can use an MCT or MCTP instruction only with a 1756-L6x
controller. |
76 | You cannot start motion that uses an S-curve profile if the
maximum deceleration jerk for the axis is zero. 1. Open the properties for the axis. 2. On the Planner tab, enter a value for the Maximum
Deceleration Jerk . | Zero Max Decel Jerk |
77 | How many axes are in your coordinate system? 2 — Use a non-mirror transform direction. 3 — Use a non-inverse transform direction. | Transform Direction Not Supported You're trying to use the mirror directions with a 3-axis
coordinate system and a non-zero base offset (X2b) or effector
offset (X2e). Mirror directions are not supported for 2-axis Coordinate
Systems. You are attempting to use either a 2 or 3-axis Cartesian,
Delta2D, Delta3D or SCARA Delta target coordinate system with
transform directions other than forward and inverse. You can use inverse mirror directions only when both these
conditions are true: You have a 3-axis coordinate system. The base offset (X2b) and end effector offset (X2e) of the X2
dimension are zero. |
78 | New check for a secondary Instruction overlap on top of an active
Stop instruction. | Not Allowed While Stopping You cannot overlap certain Motion instructions while stopping.
Wait for the first instruction to complete before starting the
second instruction. |
79 | Home your axis again. Error of Home instruction occurs, if any other motion on the axis
is encountered during the homing sequence. | Internal Homing Sequence Error Invalid Planner State If you see this error, rehome your axis in your application
program. Make sure the axis is stopped before home is attempted.
If the error persists, contact Rockwell Automation
Support. |
80 | When referencing a Scheduled Output Module, for example, the
OB16IS, make sure that the Output operand of the MAOC references
O:Data, and that the Scheduled Output Module's communication
format is set to `Scheduled Output Data per point’. | MAOC Invalid Output Operand If the MAOC output operand references an OB16IS Scheduled Output
module, two additional checks occur when the MAOC is
initiated. The Output operand must be referencing the beginning of the
module’s output data tag, 'O.Data'. The communications format of the OB16IS module must be the
default "Scheduled Output Data per Point". If either of these checks fail you see this error. ExErr#1: Invalid Data Tag Reference - The Output operand is not
pointing to the O.Data element of the module’s output data tag.
This is applicable to 5069-OB16F, 1756-OB16IEFS, 1732E-OB8M8SR,
and OB16IS modules only. ExErr#2: Invalid Module Communication Format for one of these
modules: 5069-OB16F, 1756-OB16IEFS, 1756-OB16IS, 1732E-OB8M8SR
modules. ExErr#3: CIP Sync not synchronized - Scheduled output module
reporting not synchronized to a CIP Sync master. Applicable to
the 5069-OB16F, 1756-OB16IEFS, 1732E-OB8M8SR modules only. ExErr#4: Grandmaster Clock mismatch - Scheduled output module has
different Grandmaster clock than the controller. Applicable to
the 5069-OB16F, 1756-OB16IEFS, 1732E-OB8M8SR modules only. |
81 | Error on MGSR, if a MASD or MGS (programmed) is executed while
the MGSR is still in process. Do not overlap the MASD instruction or MGS stop instruction with
Stop Mode = Programmed on an active MGSR instruction. | Partial Group Shutdown Reset. If your application program is actively executing an MGSR
instruction and you try to execute an MASD instruction or MGS
stop instruction with Stop Mode = Programmed on one of the axes
affected by the active MGSR instruction, you will see this error
on the MGSR instruction. |
82 | The axis was found to be in the incorrect operational axis
state. | CIP axis in incorrect state. |
83 | This instruction cannot be performed due to control mode or
feedback selection. | Illegal Control Mode or Method. The MDS instruction is not valid in Position Loop or Feedback
Only modes. The error also triggers when the CIP motion device does not have
a valid feedback to perform the instruction. |
84 | The CIP drive device digital input is not assigned. | Drive Digital Input Not Assigned |
85 | Instruction not allowed when redefine position is in process. Performing MAH while MRP is in process results in this
instruction error. | Homing, redefine position in progress An Active Redefine Position instruction is in process. You would get this error if any of the motion planner
instructions are executed while MRP is in progress. Motion
Instructions included are: MAM, MAJ, MCLM , MCCM, MATC, MAPC ,
MDAC, MDCC, and MCPM. |
86 | Current use of the MDS instruction requires an optional attribute
that is not supported. | Optional attribute not supported by the integrated motion drive
being used. Executing a MDS instruction on a CIP- Velocity Loop
with Feedback axis associated with a Kinetix
6500 drive errors. The instruction requires an optional
attribute that is not currently supported.The MDS instruction is not supported by the drive type. |
87 | The instruction is invalid while running direct controlled
motion. | Not Allowed While In Direct Motion |
88 | The instruction is invalid while running planned motion. | Not Allowed While Planner Active |
93 | A move was programmed in MDSC mode before the MDSC link has been
established by the execution of a MDAC or MDCC. | MDSC Not Activated |
94 | Some dynamics units belong to Leader Driven Mode and some to Time
Driven Mode. Some units are time based whereas others are velocity based, for
example, Speed in Seconds and Acceleration in units/sec2. Incompatibility of units. Dynamics in Seconds are incompatible
with Merge Speed = Current. | MDSC Units Conflict |
95 | All instructions in the queue must use a compatible Lock
Direction, for example, Position Forward Only and Immediate
Forward Only. Lock Direction = None and speed units belong to Leader Driven
Mode. | MDSC Lock Direction Conflict If you change from Time Driven mode to Leader Driven mode while
an axis is moving and Lock Direction is not Immediate Forward or
Reverse you will get error 95 MDSC Lock Direction Conflict. |
96 | MDAC (All) and MDAC (something other than All) on the same
follower. | MDSC MDAC All Conflict |
97 | Trying to replace a running Leader with a new Leader whose speed
is zero, or replacing a Follower that is moving via an MAM with
another MAM with the same or a different Leader that is not
moving. | MDSC Idle Leader and Follower Moving |
98 | The actual direction of leader axis’ motion does not match the
direction programmed by Lock Direction parameter (IMMEDIATE
FORWARD ONLY or IMMEDIATE REVERSE ONLY) when the follower is
already moving. | MDSC Lock Direction Leader Direction Mismatch |
99 | Either of these could be the reason for the error:
| MDSC Feature Not Supported |
100 | If speed is in seconds or Leader units, move must start from
rest. | Axis Not At Rest. |
101 | Return data array is either nonexistent or not big enough to
store all the requested data. | MDSC Calculated Data Size Error. |
102 | Attempt to activate a second MDSC instruction with a Lock
Position or a Merge with a Lock Position while an axis is
moving. | MDSC Lock While Moving. |
103 | If the Leader Axis is changed and the new follower speed is less
than 5% of the original follower speed for Single Axis
instructions, or 10%, depending on the move of the original
Follower Coordinate System speed, then this error will occur and
the change will not be allowed. The same applies when changing
from Time Driven mode to MDSC mode. | MDSC Invalid Follower Speed Reduction. |
104 | IF: a motion instruction performs either: A change in the Leader Axis A change in speed units AND: if in the same update period, the instruction is either forced to
pause with a speed of zero, or stopped with a MAS or MCS THEN: the velocity profile is changed to trapezoidal and this error
code is reported. | MDSC 2 Instructions were started in 1 Update Period therefore
Jerk was Maximized. |
105 | An instruction in the coordinated motion queue is either trying
to change the Leader Axis or changing the mode from MDSC mode to
Time Driven mode or from Time Driven mode to MDSC mode. | MDSC Invalid Mode Or Leader Change. |
106 | Cannot use Merge to Current when programming in time driven mode
using seconds or leader driven mode using leader units. Change merge speed parameter. | Merge to Current using seconds is illegal. |
107 | Target device does not support the requested operation, service,
or both. | There is not any corrective action that can be taken. |
108 | Coordinated System contains a multiplexed axis. | Motion coordinated instructions cannot contain multiplexed
axes. |
109 | You attempted to use an axis that is defined as a converter or
track section. | Invalid Axis Configuration A converter or track section cannot be used for this
instruction. |
110 | You attempted to put an axis configured as a converter into a
coordinate system definition. | A converter cannot be used for this instruction. |
111 | You cannot start motion if the maximum acceleration for the axis
is zero.
| Zero Max Accel |
112 | For CompactLogix 5370, ControlLogix 5570, Compact GuardLogix
5370, and GuardLogix 5570 controllers (supported by the Logix
Designer application versions 38.00 and earlier): Operand Nominal
Leader Velocity in MDC instructions must be equal to zero. | Operand not supported. |
121 | The Coordinate Definition cannot be set to <none>. | Invalid coordinate definition for the instruction. |
125 | Operand 0 must be a Cartesian coordinate system type. | Source coordinate system is not Cartesian. |
126 | Operand 1 must NOT be a Cartesian coordinate system type. | Target coordinate system is Cartesian. |
128 | Turns counter functionality is not supported. Turns counter is not supported on J1 and J4 on 4 axis geometries
and J1 and J6 on 5 axis geometries. Turns counter functionality is not supported when transform is
disabled. | Turns Counter Not Supported. |
130 | Cannot use the Coordinate system that supports orientation with
MCLM, MCCM and MCCD instructions. Corrective action: 1. Modify the coordinate definition of the Cartesian coordinate
system to <none> OR 2. Use the configured Cartesian Coordinate system XYZRxRyRz with
the MCPM instruction which supports orientation axes
control. | Not allowed on the orientation supported geometries. |
132 | Operands of MCS should be set as follows. Otherwise the
instruction will error. 1. If Change Decel is set to Yes , then Decel
Units must be % of Maximum . Units per Sec2 is not
acceptable because different decel value is needed for Cartesian
and orientation axes.2. Change Decel Jerk must be set to Yes . Setting it
to No is not acceptable because different jerk value is
needed for Cartesian and orientation axes.3. Decel Jerk Units must be programmed in % of
time . Units per Sec3 and % of Maximum, are not acceptable
because different value is needed for Cartesian and orientation
axes. | MCS Units conflict. |
135 | If MCPM speed, accel or decel units are programmed in % of max
and the associated leader driven MDCC instruction nominal leader
velocity is set to zero, the instruction will error. | MCPM zero nominal leader velocity. |
136 | There are two possible situations that can result in this
conflict:
| MCPM robot configuration conflict. |
137 | The robot configuration parameter for the MCTPO instruction is
not valid for this Robot geometry. | Invalid robot configuration. |
138 | Refer to the extended error codes in the online help for the MCPM
instruction for details related to this error code. | MCPM path data invalid value. |
139 | Refer to the extended error codes in the online help for the MCPM
instruction for details related to this error code. | MCPM Dynamics Data invalid value. |
140 | Wait until the Servo On operation is complete. | Servo On in progress. |
141 | Wait until the Servo Off operation is complete. | Servo Off in progress. |
142 | Wait for the Shutdown Reset operation to complete. | Shutdown Reset in progress. |
143 | Wait for Axis Homing to complete. | Home in progress. |
144 | Wait for the Motion redefine position operation to complete. | Redefine in progress. |
145 | Wait for the Shutdown operation to complete. | Shutdown in progress. |
146 | Cannot start motion if the maximum orientation deceleration for
the coordinate system is zero. | Maximum orientation deceleration is zero. |
147 | A orientation axis (Rx, Ry, or Rz) in the coordinate system has
one of the following:
Refer to the online help for the instruction for extended error
code definitions. It identifies the orientation axis. | Invalid orientation scaling constant. |
148 | The MCTO or MCTPO instruction reports this error when the
Orientation offset is not valid when:
Refer to the online help for the instruction for extended error
code definitions. It identifies the orientation axis. | MCTO or MCTPO orientation offset is not zero. |
149 | Orientation axes (Rx, Ry, and Rz) must be virtual if the
coordinate system is involved in the MCTO or MCTPO
transforms. Refer to the online help for the instruction for extended error
code definitions. It identifies the orientation axis. | Orientation axis is not virtual. |
150 | The instruction reports this error when an orientation axis (Rx,
Ry, or Rz) is used as a leader axis of a gearing, camming, or
leader driven instructions | Leader axis is orientation axis. |
151 | The Joint angle in a Delta J1JJ2J6, DeltaJ1J2J3J6, or Delta
J1J2J3J4J5 geometry goes beyond the joint angle limit. Refer to the online help for the instruction for extended error
code definitions. It identifies the Joint that is outside its
range. | Joint angle beyond its limits. |
152 | Error occurs when the orientation axis is commanded to move by
and angle greater than or equal to 180 degrees in one coarse
update period. Refer to the online help for the instruction for extended error
code definitions. It identifies the orientation axis. | Maximum orientation speed exceeded for an orientation axis. |
153 | The error occurs if the programmed Cartesian position (X, Y or Z)
cannot be attained by the robot. For example: A Delta J1J2J6 robot can operate only in a 2D X-Z
plane without a tool. If you program a Cartesian point with Y, a
non-zero value, this error occurs with extended error 2 that
represents invalid translation position Y. Refer to the online help for the instruction for extended error
code definitions. It identifies the Joint that is outside its
range. | Invalid translation position. |
155 | MCPM currently does not support any action on 6-axis robot
geometry, so if attempted this error occurs. | Robot geometry is not supported in MCPM. |
170 | The instruction reports this error when a cam replacement is
attempted when there is no active cam. | |
171 | The error occurs when attempting to replace a cam and replacement
point not in range of cam profile. | |
172 | Attempting to replace a cam when Execution Schedule is
“Pending”. | The cam type is “Replace and Restart” or “Replace and continue”
and the Execution Schedule is “Pending”. Execution Schedule of “Pending” is only associated with cam type
“New Cam”. |
173 | Cam completed before crossing the replacement position. | 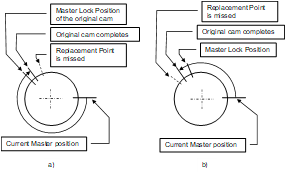 |
174 | The start point for cam replacement is beyond existing cam
boundary. | 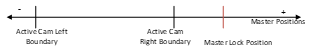 Example: An Active cam is locked, and Leader Lock Position of a
replacement cam is set to a point beyond the right cam
boundary. |
176 | Motion Calculate Follower Values (MCSV) cannot find a Leader value
for the supplied Follower value. | |
178 | Selected “Cam Type” is not supported. | |
179 | The instruction reports this error when the cam profile array
operand contains an invalid value (such as overflow or not a
number). Use the Motion Calculate Cam Profile (MCCP) instruction or Cam
Profile Editor to recalculate the cam profile and confirm that
the leader and follower values do not contain an invalid value. | For MATC, MAPC, and MCSV instructions, the .SEGMENT field of
Motion Instruction identifies which cam profile element contains
the invalid value. A .SEGMENT = 3 means the fourth element (or [3]) of the Cam
Profile array contains the invalid number. Check the Leader,
Follower, C0, C1, C2, and C3 values of the Cam Profile array
element. |
190 | Direct command operation has been inhibited | The Direct Command is prevented from executing. The
Direct Command Inhibit is enabled for the axis,
preventing this operation. |
You will get an error if certain Motion Instructions overlap while Motion Stop
Instructions are active. In this case, an instruction is actively stopping and a
second instruction is initiated that overlaps the active instruction. The table
below lists some of the overlap instances that will generate errors.
In this case:
Error # 7 = Shutdown State Error.
Error #61, ExErr #10 = Connection Conflict, Transform Axes Moving or Locked By Other
Operation.
Error #78 = Not Allowed While Stopping.
Generated Errors in Overlap Instances
The following table lists additional overlap instances that will generate errors.
Active Stopping Instruction | |||||||||
MGS | MGSD | MCS | MAS | ||||||
Initiated Second Instruction | Stop Mode = Fast Stop | Stop Mode = Fast Disable | Stop Mode = Programmed | Stop Type = Coordinated Move | Stop Type = Coordinated Transform | Stop Type = All | All Stop Types Except StopType =
All | Stop Type = All | |
MAAT | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | Error #78 | Error #78 | Error #78 |
MRAT | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | Error #78 | Error #78 | Error #78 |
MAHD | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | Error #78 | Error #78 | Error #78 |
MRHD | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | Error #78 | Error #78 | Error #78 |
MAH | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | Error #78 | Error #78 | Error #78 |
MAJ | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | |||
MAM | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | |||
MAG | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | |||
MCD | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | Error #78 | Error #78 | Error #78 |
MAPC | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | |||
MATC | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | |||
MDO | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | |||
MCT | Error #78 | Error #78 | Error #78 | Error # 7 | Error #61 ExErr #10 | Error #61 ExErr #10 | Error #61 ExErr #10 | Error #61 ExErr #10 | Error #61 ExErr #10 |
MCTO | Error #78 | Error #78 | Error #78 | Error #7 | Error #61 ExErr #10 | Error #61 ExErr #10 | Error #61 ExErr #10 | Error #61 ExErr #10 | Error #61 ExErr #10 |
MCCD | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | |||
MCLM/MCCM (Merge = Disabled) | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | Error #78 | Error #78 | |
MCLM/MCCM (Merge=Enabled) | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | Error #78 | ||
MCPM | Error #78 | Error #78 | Error #78 | Error # 7 | Error #78 | Error #78 | Error #78 | Error #78 | |
Additional Generated Errors in Overlap Instances
Active Stopping Instruction | ||||||||
MGS | MGSD | MCS | MAS | MASD | ||||
Initiated Second Instruction | Stop Type | Stop Mode = Fast Stop | Stop Mode = Fast Disable | Stop Mode = Programmed | None | Stop Type = All | Stop Type = All | None |
MGS | Stop Mode = Fast Stop | Error #78 | Error #78 | Error #78 | Error #7 | |||
Stop Mode = Fast Disable | Error #78 | Error #78 | Error #78 | Error #7 | ||||
Stop Mode = Programmed | Error #78 | Error #78 | Error #78 | Error #7 | ||||
MGSR | None | Error #78 | Error #78 | Error #78 | Error #7 | Error #7 | ||
MCS | Stop Type = Coordinated Move | Error #78 | Error #78 | Error #78 | Error #7 | Error #78 | Error #78 | |
Stop Type = Coordinated Transform | Error #78 | Error #78 | Error #78 | Error #7 | Error #78 | Error #78 | ||
All Stop Types Except StopType = All | Error #78 | Error #78 | Error #78 | Error #7 | ||||
MAS | Stop Type!= All | Error #78 | Error #78 | Error #78 | Error #7 | Error #78 | Error #78 | Error #7 |
Stop Type = All | Error #78 | Error #78 | Error #78 | Error #7 | Error #7 | |||
MASR | None | Error #78 | Error #78 | Error #78 | Error #7 | Error #7 | ||
Provide Feedback